

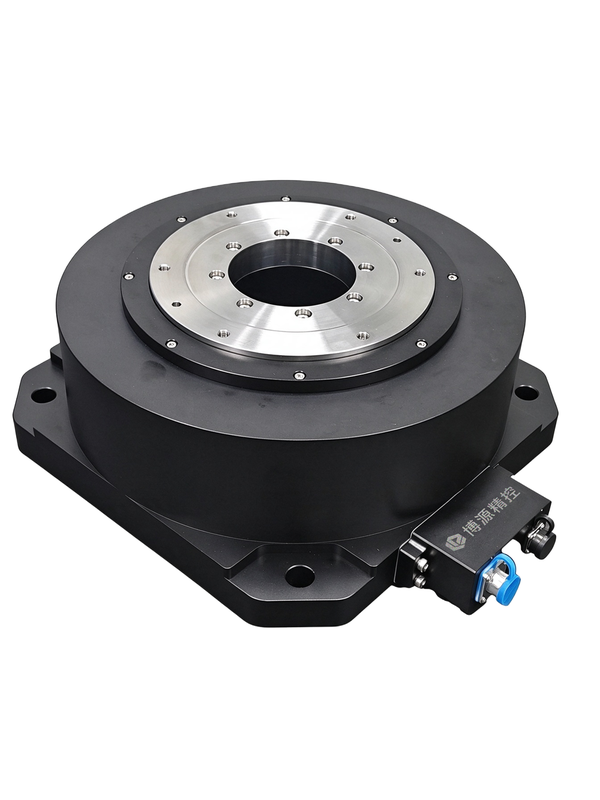
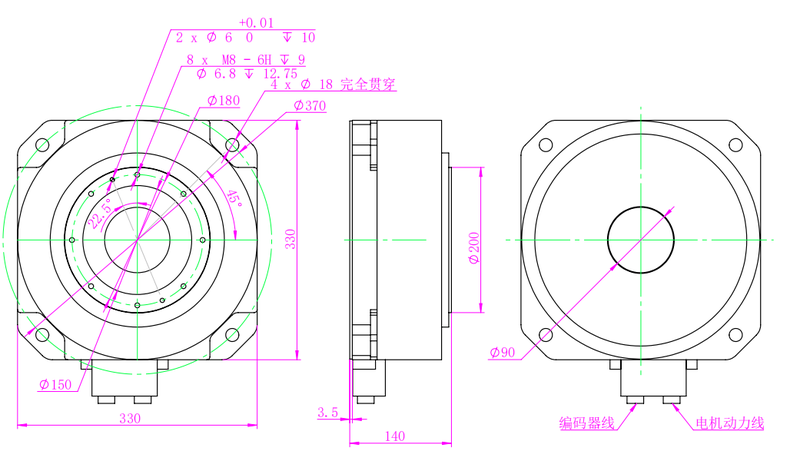
BYWDD-330-140
High precision potential: DD motors generally integrate high-resolution encoders, with absolute encoders reaching 23 bits or more. Full closed-loop control provides repeatability of ±1-2 arcsec, difficult to maintain with conventional servo-and-reducer systems because of backlash and wear. High stiffness and rapid response: mounting the load directly on the rotor shortens transmission and increases servo stiffness. Millisecond settling reduces waiting during frequent starts, stops, and rapid positioning in wafer inspection or sorting. Smooth low-speed motion without stick-slip: low-speed scanning or fine adjustment has less velocity fluctuation and better positional stability than geared servo systems. Compact and low maintenance: no wear-prone belts or gears, virtually no routine maintenance, and a large hollow bore simplifies cabling and layout. Resolution row: the unit field reads absolute boss-c protocol; the value field is empty.
 Save to Favorites
Overview
Specifications
| Parameter | Value |
|---|---|
| Continuous Torque | 79.2 N.m |
| Continuous Current | 6 Arms |
| Maximum Torque | 200 N.m |
| Maximum Current | 18 Arms |
| Torque Constant | 6.6 Nm/Arms |
| Electrical Resistance [25℃] | 10.8 Ω |
| Inductance [25℃] | 45.5 mH |
| Moment of inertia | 0.076 Kg.m² |
| Motor Weight | 36 Kg |
| Rated Speed | 100 rpm |
| Positioning Accuracy | ±10 Arc sec |
| Repeatability | ±2 Arc sec |
| Radial Runout | 10 um |
| Axial runout | 10 um |
| Maximum Axial Load | 1000 N |
| Maximum Radial Load | 1000 N |
Datasheet
Please provide your email to download the datasheet.
Invalid email format. Please try again.
Supplier Information
Related Products
-
BM150-01 Motorized Stages Chinaddwy
Locking hole P.C.D: Φ12 Height: 55.7 mm Travel: ±6.5
Maximum travel is referenced to the table's central position. Optional tabletop/base materials S50C or S50C+ with quenching and tempering to HRC28-32. S50C or S50C+ quenched and tempered to HRC28-32, with optional electroless nickel or black surface treatment. Aluminum-alloy material with black oxidation.
-
BM150-02 Motorized Stages Chinaddwy
Locking hole P.C.D: Φ12 Height: 55.7 mm Travel: ±6.5 mm
Maximum travel is referenced to the table's central position. Optional tabletop/base materials S50C or S50C+ with quenching and tempering to HRC28-32. S50C or S50C+ quenched and tempered to HRC28-32, with optional electroless nickel or black surface treatment. Aluminum-alloy material with black oxidation.
-
Digitally focused cutting head DI3000A Motorized Stages Qilinlaser
Power Handling (Power): 3000 W Collimating focal length (Collimating Length): F75 Focusing focal length (Focusing Length): F100/125/150
Product: Digital-focus cutting head. English name: Digital Focusing Cutting Head. Model DI3000A. Convenient motorized adjustment; digital display and data memory for easy identification; D30 or D38 composite lenses rated for 3000W; easy drawer-mounted protective-optic replacement; optimized optics, water cooling, and multiple seals for durability and stability; compatibility with different fiber lasers.
-
Various other lifting stages Motorized Stages Central-laser
Lifting column dimensions [Model=CK-HLD-L600; Type=Lifting worktable; Name=Extra-heavy-duty lifting worktable (version A); Original table product column=1]: 740 mm × 290 mm × 180 mm Lifting column weight [Model=CK-HLD-L600; Type=Lifting worktable; Name=Extra-heavy-duty lifting worktable (version A); Original table product column=1]: 14.05 kg Worktable dimensions [Model=CK-HLD-L600; Type=Lifting worktable; Name=Extra-heavy-duty lifting worktable (version A); Original table product column=1]: 790 mm × 700 mm × 755 mm
Selection table for 8 other lifting-stage models, including extra-heavy-duty and light-duty lifting worktables, extra-heavy-duty/light-duty flat lifting stages, and vertical heavy-duty lifting stages. All-aluminum construction and stable load support for mounting CO2, fiber, ultraviolet, green, and other lasers and for large-format marking.
-
Large-format motorized lifting stage Motorized Stages Central-laser
Applicable marking area [Model=CK-H-147C; Type A]: 300-800 mm Cabinet dimensions (length, width, height) [Model=CK-H-147C; Type A]: 58 cm × 44 cm × 82.5 cm Variable Z-axis travel range [Model=CK-H-147C; Type A]: 85~145 cm
Large-format motorized lifting stage, types A/B/C. Rust-resistant all-aluminum-profile construction, adjustable leveling feet for stability, and easy movement. Electrically triggered external lifting control, with Z travel of 85–230cm, for Z-axis lifting with marking formats of 300–1700mm.
Related Articles
The LZFL405‑80mW‑3 series from Shenzhen Leirte Optoelectronics Co., Ltd. is a coaxial‑packaged violet‑blue single‑mode fiber‑coupled laser diode. It delivers 80 mW continuous‑wave output at 405 nm. Light is coupled into 3 μm core‑diameter single‑mode fiber for clean beam quality and easy integration into diverse optical systems. It serves as a compact violet‑blue light source for medical instruments and industrial printing applications.
Wuhan Optics Valley Quantum Technology Co., Ltd. is a leading domestic developer of high‑speed semiconductor optical chips and photodetector components. Our product portfolio covers InGaAs avalanche photodiode bare dies and PIN photodetector chips designed for fiber‑optic communication
As a professional ultraviolet‑laser solution provider, Precilasers has launched its 266 nm narrow‑linewidth industrial laser, delivering reliable single‑frequency output for high‑precision interference lithography, semiconductor inspection and precision metrology applications.
Electro-optic deflectors (EODs) are optical devices used to steer or deflect light beams by applying an electric field to a specialized optical crystal. Unlike mechanical beam steering systems that rely on moving mirrors, electro-optic deflectors enable high-speed, non-mechanical beam control with exceptional precision and responsiveness. They are widely used in laser scanning, optical communications, microscopy, laser printing, spectroscopy, and scientific research, where rapid and accurate laser beam positioning is essential.
Loading...
Name
Phone
Organization
Use Case

Database Platform